Class to provide general functionality of a Dome device. More...
#include <indidome.h>
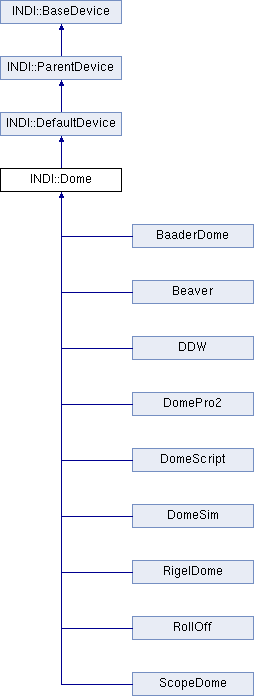
Public Member Functions | |
| Dome () | |
| virtual | ~Dome () |
| virtual bool | initProperties () override |
| Initialize properties initial state and value. The child class must implement this function. | |
| virtual void | ISGetProperties (const char *dev) override |
| define the driver's properties to the client. Usually, only a minimum set of properties are defined to the client in this function if the device is in disconnected state. Those properties should be enough to enable the client to establish a connection to the device. In addition to CONNECT/DISCONNECT, such properties may include port name, IP address, etc. You should check if the device is already connected, and if this is true, then you must define the remainder of the the properties to the client in this function. Otherwise, the remainder of the driver's properties are defined to the client in updateProperties() function which is called when a client connects/disconnects from a device. | |
| virtual bool | updateProperties () override |
| updateProperties is called whenever there is a change in the CONNECTION status of the driver. This will enable the driver to react to changes of switching ON/OFF a device. For example, a driver may only define a set of properties after a device is connected, but not before. | |
| virtual bool | ISNewNumber (const char *dev, const char *name, double values[], char *names[], int n) override |
| Process the client newNumber command. | |
| virtual bool | ISNewSwitch (const char *dev, const char *name, ISState *states, char *names[], int n) override |
| Process the client newSwitch command. | |
| virtual bool | ISNewText (const char *dev, const char *name, char *texts[], char *names[], int n) override |
| Process the client newSwitch command. | |
| virtual bool | ISSnoopDevice (XMLEle *root) override |
| Process a snoop event from INDI server. This function is called when a snooped property is updated in a snooped driver. | |
| void | setDomeConnection (const uint8_t &value) |
| setDomeConnection Set Dome connection mode. Child class should call this in the constructor before Dome registers any connection interfaces | |
| uint8_t | getDomeConnection () const |
| uint32_t | GetDomeCapability () const |
| GetDomeCapability returns the capability of the dome. | |
| void | SetDomeCapability (uint32_t cap) |
| SetDomeCapability set the dome capabilities. All capabilities must be initialized. | |
| bool | CanAbort () |
| bool | CanAbsMove () |
| bool | CanRelMove () |
| bool | CanPark () |
| bool | CanSync () |
| bool | HasShutter () |
| bool | HasVariableSpeed () |
| bool | HasBacklash () |
| bool | isLocked () |
| isLocked, is the dome currently locked? | |
| DomeState | getDomeState () const |
| void | setDomeState (const DomeState &value) |
| ShutterState | getShutterState () const |
| void | setShutterState (const ShutterState &value) |
| IPState | getMountState () const |
 Public Member Functions inherited from INDI::DefaultDevice | |
| DefaultDevice () | |
| virtual | ~DefaultDevice () override=default |
| void | addAuxControls () |
| Add Debug, Simulation, and Configuration options to the driver. | |
| void | addDebugControl () |
| Add Debug control to the driver. | |
| void | addSimulationControl () |
| Add Simulation control to the driver. | |
| void | addConfigurationControl () |
| Add Configuration control to the driver. | |
| void | addPollPeriodControl () |
| Add Polling period control to the driver. | |
| void | addNicknameControl () |
| Add Nickname text property to the driver. | |
| void | resetProperties () |
| Set all properties to IDLE state. | |
| void | defineNumber (INumberVectorProperty *nvp) |
| Define number vector to client & register it. Alternatively, IDDefNumber can be used but the property will not get registered and the driver will not be able to save configuration files. | |
| void | defineProperty (INumberVectorProperty *property) |
| void | defineText (ITextVectorProperty *tvp) |
| Define text vector to client & register it. Alternatively, IDDefText can be used but the property will not get registered and the driver will not be able to save configuration files. | |
| void | defineProperty (ITextVectorProperty *property) |
| void | defineSwitch (ISwitchVectorProperty *svp) |
| Define switch vector to client & register it. Alternatively, IDDefswitch can be used but the property will not get registered and the driver will not be able to save configuration files. | |
| void | defineProperty (ISwitchVectorProperty *property) |
| void | defineLight (ILightVectorProperty *lvp) |
| Define light vector to client & register it. Alternatively, IDDeflight can be used but the property will not get registered and the driver will not be able to save configuration files. | |
| void | defineProperty (ILightVectorProperty *property) |
| void | defineBLOB (IBLOBVectorProperty *bvp) |
| Define BLOB vector to client & register it. Alternatively, IDDefBLOB can be used but the property will not get registered and the driver will not be able to save configuration files. | |
| void | defineProperty (IBLOBVectorProperty *property) |
| void | defineProperty (INDI::Property &property) |
| virtual bool | deleteProperty (const char *propertyName) |
| Delete a property and unregister it. It will also be deleted from all clients. | |
| bool | deleteProperty (INDI::Property &property) |
| deleteProperty Delete a property and unregister it. It will also be deleted from all clients. | |
| virtual void | setConnected (bool status, IPState state=IPS_OK, const char *msg=nullptr) |
| Set connection switch status in the client. | |
| int | SetTimer (uint32_t ms) |
| Set a timer to call the function TimerHit after ms milliseconds. | |
| void | RemoveTimer (int id) |
| Remove timer added with SetTimer. | |
| virtual void | TimerHit () |
| Callback function to be called once SetTimer duration elapses. | |
| virtual const char * | getDriverExec () |
| virtual const char * | getDriverName () |
| void | setVersion (uint16_t vMajor, uint16_t vMinor) |
| Set driver version information to be defined in DRIVER_INFO property as vMajor.vMinor. | |
| uint16_t | getMajorVersion () const |
| uint16_t | getMinorVersion () const |
| virtual bool | ISNewBLOB (const char *dev, const char *name, int sizes[], int blobsizes[], char *blobs[], char *formats[], char *names[], int n) |
| Process the client newBLOB command. | |
| bool | ISNewProperty (INDI::Property &property, const std::string &elementName, const std::any &value) |
| Generic convenience function to update a property element as if by client request, simulating an ISNew... call. | |
| template<typename PropertyType , typename ValueType > | |
| bool | updateProperty (PropertyType &property, ValueType *values, char *names[], int n, std::function< bool()> updater, bool saveConfig=false) |
| Generic helper function to update an INDI property based on an external operation. | |
| uint32_t | getDriverInterface () const |
| void | setDriverInterface (uint32_t value) |
| setInterface Set driver interface. By default the driver interface is set to GENERAL_DEVICE. You may send an ORed list of DeviceInterface values. | |
| void | watchDevice (const char *deviceName, const std::function< void(INDI::BaseDevice)> &callback) |
| Add a device to the watch list. | |
| Public Member Functions inherited from INDI::ParentDevice | |
| ParentDevice (Type type) | |
| ~ParentDevice () | |
| ParentDevice (ParentDevice &&other)=default | |
| ParentDevice & | operator= (ParentDevice &&other)=default |
| Public Member Functions inherited from INDI::BaseDevice | |
| BaseDevice () | |
| virtual | ~BaseDevice () |
| void | registerProperty (const INDI::Property &property) |
| Register the property to be able to observe and update. | |
| void | registerProperty (const INDI::Property &property, INDI_PROPERTY_TYPE type) |
| int | removeProperty (const char *name, char *errmsg) |
| Remove a property. | |
| void | watchProperty (const char *name, const std::function< void(INDI::Property)> &callback, WATCH watch=WATCH_NEW) |
| Call the callback function if property is available. | |
| Property | getProperty (const char *name, INDI_PROPERTY_TYPE type=INDI_UNKNOWN) const |
| Return a property and its type given its name. | |
| Properties | getProperties () |
| Return a list of all properties in the device. | |
| const Properties | getProperties () const |
| INDI::PropertyNumber | getNumber (const char *name) const |
| INDI::PropertyText | getText (const char *name) const |
| INDI::PropertySwitch | getSwitch (const char *name) const |
| INDI::PropertyLight | getLight (const char *name) const |
| INDI::PropertyBlob | getBLOB (const char *name) const |
| IPState | getPropertyState (const char *name) const |
| IPerm | getPropertyPermission (const char *name) const |
| void * | getRawProperty (const char *name, INDI_PROPERTY_TYPE type=INDI_UNKNOWN) const |
| Return a property and its type given its name. | |
| void | addMessage (const std::string &msg) |
| Add message to the driver's message queue. | |
| void | checkMessage (XMLEle *root) |
| void | doMessage (XMLEle *msg) |
| const std::string & | messageQueue (size_t index) const |
| const std::string & | lastMessage () const |
| bool | isValid () const |
| bool | isSameDevice (const BaseDevice &other) const |
| bool | isConnected () const |
| void | attach () |
| indicates that the device is ready | |
| void | detach () |
| indicates that the device is being removed | |
| void | setMediator (INDI::BaseMediator *mediator) |
| Set the driver's mediator to receive notification of news devices and updated property values. | |
| INDI::BaseMediator * | getMediator () const |
| void | setDeviceName (const char *dev) |
| Set the device name. | |
| const char * | getDeviceName () const |
| bool | isDeviceNameMatch (const char *otherName) const |
| Check that the device name matches the argument. | |
| bool | isDeviceNameMatch (const std::string &otherName) const |
| Check that the device name matches the argument. | |
| const char * | getDriverName () const |
| const char * | getDriverExec () const |
| const char * | getDriverVersion () const |
| uint16_t | getDriverInterface () const |
| getDriverInterface returns ORed values of DRIVER_INTERFACE. It presents the device classes supported by the driver. | |
| bool | buildSkeleton (const char *filename) |
| Build driver properties from a skeleton file. | |
| int | buildProp (const INDI::LilXmlElement &root, char *errmsg, bool isDynamic=false) |
| Build a property given the supplied XML element (defXXX) | |
| int | setValue (const INDI::LilXmlElement &root, char *errmsg) |
| handle SetXXX commands from client | |
| operator BaseDevice * () | |
| BaseDevice * | operator-> () |
| bool | operator!= (std::nullptr_t) const |
| bool | operator== (std::nullptr_t) const |
| operator bool () const | |
| operator bool () | |
Static Public Member Functions | |
| static void | buttonHelper (const char *button_n, ISState state, void *context) |
| Static Public Member Functions inherited from INDI::BaseDevice | |
| static std::string | getSharedFilePath (std::string fileName) |
Public Attributes | |
| enum INDI::Dome:: { ... } | DomeConnection |
Protected Types | |
| enum | { ACTIVE_MOUNT , ACTIVE_INPUT , ACTIVE_OUTPUT } |
| enum | { SHUTTER_CLOSE_ON_PARK , SHUTTER_OPEN_ON_UNPARK } |
| enum | { DM_OTA_SIDE_EAST , DM_OTA_SIDE_WEST , DM_OTA_SIDE_MOUNT , DM_OTA_SIDE_HA , DM_OTA_SIDE_IGNORE } |
Protected Member Functions | |
| virtual bool | SetSpeed (double rpm) |
| SetSpeed Set Dome speed. This does not initiate motion, it sets the speed for the next motion command. If motion is in progress, then change speed accordingly. | |
| virtual IPState | Move (DomeDirection dir, DomeMotionCommand operation) |
| Move the Dome in a particular direction. | |
| virtual IPState | MoveAbs (double az) |
| Move the Dome to an absolute azimuth. | |
| virtual IPState | MoveRel (double azDiff) |
| Move the Dome to an relative position. | |
| virtual bool | Sync (double az) |
| Sync sets the dome current azimuth as the supplied azimuth position. | |
| virtual bool | Abort () |
| Abort all dome motion. | |
| virtual IPState | Park () |
| Goto Park Position. The park position is an absolute azimuth value. | |
| virtual IPState | UnPark () |
| UnPark dome. The action of the Unpark command is dome specific, but it may include opening the shutter and moving to home position. When UnPark() is successful The observatory should be in a ready state to utilize the mount to perform observations. | |
| virtual bool | SetBacklash (int32_t steps) |
| SetBacklash Set the dome backlash compensation value. | |
| virtual bool | SetBacklashEnabled (bool enabled) |
| SetBacklashEnabled Enables or disables the dome backlash compensation. | |
| virtual IPState | ControlShutter (ShutterOperation operation) |
| Open or Close shutter. | |
| const char * | GetShutterStatusString (ShutterState status) |
| getShutterStatusString | |
| void | SetParkDataType (DomeParkData type) |
| setParkDataType Sets the type of parking data stored in the park data file and presented to the user. | |
| bool | InitPark () |
| InitPark Loads parking data (stored in ~/.indi/ParkData.xml) that contains parking status and parking position. InitPark() should be called after successful connection to the dome on startup. | |
| bool | isParked () |
| isParked is dome currently parked? | |
| void | SetParked (bool isparked) |
| SetParked Change the mount parking status. The data park file (stored in ~/.indi/ParkData.xml) is updated in the process. | |
| double | GetAxis1Park () |
| double | GetAxis1ParkDefault () |
| void | SetAxis1Park (double value) |
| SetRAPark Set current AZ parking position. The data park file (stored in ~/.indi/ParkData.xml) is updated in the process. | |
| void | SetAxis1ParkDefault (double steps) |
| SetAxis1Park Set default AZ parking position. | |
| virtual bool | SetCurrentPark () |
| SetCurrentPark Set current coordinates/encoders value as the desired parking position. | |
| virtual bool | SetDefaultPark () |
| SetDefaultPark Set default coordinates/encoders value as the desired parking position. | |
| const char * | LoadParkData () |
| bool | WriteParkData () |
| bool | GetTargetAz (double &Az, double &Alt, double &minAz, double &maxAz) |
| GetTargetAz. | |
| bool | Intersection (point3D p1, point3D p2, double r, double &mu1, double &mu2) |
| Intersection Calculate the intersection of a ray and a sphere. The line segment is defined from p1 to p2. The sphere is of radius r and centered at (0,0,0). From http://local.wasp.uwa.edu.au/~pbourke/geometry/sphereline/ There are potentially two points of intersection given by p := p1 + mu1 (p2 - p1) p := p1 + mu2 (p2 - p1) | |
| bool | OpticalCenter (point3D MountCenter, double dOpticalAxis, double Lat, double Ah, point3D &OP) |
| OpticalCenter This function calculates the distance from the optical axis to the Dome center. | |
| bool | OpticalVector (double Az, double Alt, point3D &OV) |
| OpticalVector This function calculates a second point for determining the optical axis. | |
| bool | CheckHorizon (double HA, double dec, double lat) |
| CheckHorizon Returns true if telescope points above horizon. | |
| virtual bool | saveConfigItems (FILE *fp) override |
| saveConfigItems Saves the Device Port and Dome Presets in the configuration file | |
| void | UpdateMountCoords () |
| updateCoords updates the horizontal coordinates (Az & Alt) of the mount from the snooped RA, DEC and observer's location. | |
| virtual void | UpdateAutoSync () |
| UpdateAutoSync This function calculates the target dome azimuth from the mount's target coordinates given the dome parameters. If the difference between the dome's and mount's azimuth angles exceeds the AutoSync threshold, the dome will be commanded to sync to the mount azimuth position. | |
| virtual bool | Handshake () |
| perform handshake with device to check communication | |
| virtual void | ActiveDevicesUpdated () |
| double | Csc (double x) |
| double | Sec (double x) |
| Protected Member Functions inherited from INDI::DefaultDevice | |
| void | setDynamicPropertiesBehavior (bool defineEnabled, bool deleteEnabled) |
| setDynamicPropertiesBehavior controls handling of dynamic properties. Dynamic properties are those generated from an external skeleton XML file. By default all properties, including dynamic properties, are defined to the client in ISGetProperties(). Furthermore, when űdeleteProperty(properyName) is called, the dynamic property is deleted by default, and can only be restored by calling buildSkeleton(filename) again. However, it is sometimes desirable to skip the definition of the dynamic properties on startup and delegate this task to the child class. To control this behavior, set enabled to false. | |
| virtual bool | loadConfig (bool silent=false, const char *property=nullptr) |
| Load the last saved configuration file. | |
| bool | loadConfig (INDI::Property &property) |
| Load property config from the configuration file. If the property configuration is successfully parsed, the corresponding ISNewXXX is called with the values parsed from the config file. | |
| virtual bool | saveConfig (bool silent=false, const char *property=nullptr) |
| Save the current properties in a configuration file. | |
| bool | saveConfig (INDI::Property &property) |
| Save a property in the configuration file. | |
| virtual bool | purgeConfig () |
| purgeConfig Remove config file from disk. | |
| virtual bool | saveAllConfigItems (FILE *fp) |
| saveAllConfigItems Save all the drivers' properties in the configuration file | |
| virtual bool | loadDefaultConfig () |
| Load the default configuration file. | |
| void | setDebug (bool enable) |
| Toggle driver debug status A driver can be more verbose if Debug option is enabled by the client. | |
| void | setSimulation (bool enable) |
| Toggle driver simulation status A driver can run in simulation mode if Simulation option is enabled by the client. | |
| virtual void | debugTriggered (bool enable) |
| Inform driver that the debug option was triggered. This function is called after setDebug is triggered by the client. Reimplement this function if your driver needs to take specific action after debug is enabled/disabled. Otherwise, you can use isDebug() to check if simulation is enabled or disabled. | |
| virtual void | simulationTriggered (bool enable) |
| Inform driver that the simulation option was triggered. This function is called after setSimulation is triggered by the client. Reimplement this function if your driver needs to take specific action after simulation is enabled/disabled. Otherwise, you can use isSimulation() to check if simulation is enabled or disabled. | |
| bool | isDebug () const |
| bool | isSimulation () const |
| virtual bool | Connect () |
| Connect to the device. INDI::DefaultDevice implementation connects to appropriate connection interface (Serial or TCP) governed by connectionMode. If connection is successful, it proceed to call Handshake() function to ensure communication with device is successful. For other communication interface, override the method in the child class implementation. | |
| virtual bool | Disconnect () |
| Disconnect from device. | |
| void | registerConnection (Connection::Interface *newConnection) |
| registerConnection Add new connection plugin to the existing connection pool. The connection type shall be defined to the client in ISGetProperties() | |
| bool | unRegisterConnection (Connection::Interface *existingConnection) |
| unRegisterConnection Remove connection from existing pool | |
| Connection::Interface * | getActiveConnection () |
| void | setActiveConnection (Connection::Interface *existingConnection) |
| setActiveConnection Switch the active connection to the passed connection plugin | |
| void | setDefaultPollingPeriod (uint32_t msec) |
| setDefaultPollingPeriod Change the default polling period to call TimerHit() function in the driver. | |
| void | setPollingPeriodRange (uint32_t minimum, uint32_t maximum) |
| setPollingPeriodRange Set the range permitted by the polling range in milliseconds | |
| uint32_t | getPollingPeriod () const |
| getPollingPeriod Return the polling period. | |
| void | setCurrentPollingPeriod (uint32_t msec) |
| setCurrentPollingPeriod Change the current polling period to call TimerHit() function in the driver. | |
| uint32_t | getCurrentPollingPeriod () const |
| getCurrentPollingPeriod Return the current polling period. | |
| uint32_t & | refCurrentPollingPeriod () __attribute__((deprecated)) |
| uint32_t | refCurrentPollingPeriod () const __attribute__((deprecated)) |
| bool | isConfigLoading () const |
| isConfigLoading Check if driver configuration is currently in the process of getting loaded. | |
| bool | isInitializationComplete () const |
| isInitializationComplete Check if driver initialization is complete. | |
| void | syncDriverInfo () |
| syncDriverInfo sends the current driver information to the client. | |
| virtual const char * | getDefaultName ()=0 |
| void | setDeviceNickname (const char *nick) |
| Set the device nickname. | |
| const char * | getDeviceNickname () |
| const char * | lookupDeviceNicknameFromId (const char *identifier, const char *device=nullptr) |
| Lookup device nickname for an identifier. | |
| bool | setDeviceNicknameFromId (const char *identifier) |
| Set device nickname based on an identifier. | |
| void | saveNicknameId (const char *nickname, const char *identifier) |
| virtual void | nicknameSet (const char *nickname) |
| Inform driver that the nickname has been set. | |
| DefaultDevice (const std::shared_ptr< DefaultDevicePrivate > &dd) | |
| Protected Member Functions inherited from INDI::ParentDevice | |
| ParentDevice (const std::shared_ptr< ParentDevicePrivate > &dd) | |
| Protected Member Functions inherited from INDI::BaseDevice | |
| BaseDevice (BaseDevicePrivate &dd) | |
| BaseDevice (const std::shared_ptr< BaseDevicePrivate > &dd) | |
Detailed Description
Class to provide general functionality of a Dome device.
Both relative and absolute position domes are supported. Furthermore, if no position feedback is available from the dome, an open-loop control is possible with simple direction commands (Clockwise and counter clockwise).
Before using any of the dome functions, you must define the capabilities of the dome by calling SetDomeCapability() function. All positions are represented as degrees of azimuth.
Relative motion is specified in degrees as either positive (clock wise direction), or negative (counter clock-wise direction).
Slaving is used to synchronizes the dome's azimuth position with that of the mount. The mount's coordinates are snooped from the active mount that has its name specified in ACTIVE_TELESCOPE property in the ACTIVE_DEVICES vector. Dome motion begins when it receives TARGET_EOD_COORD property from the mount driver when the mount starts slewing to the desired target coordinates /em OR when the mount's current tracking position exceeds the AutoSync threshold. Therefore, slaving is performed while slewing and tracking. The user is required to fill in all required parameters before slaving can be used. The AutoSync threshold is the difference in degrees between the dome's azimuth angle and the mount's azimuth angle that should trigger a dome motion. By default, it is set to 0.5 degrees which would trigger dome motion due to any difference between the dome and mount azimuth angles that exceeds 0.5 degrees. For example, if the threshold is set to 5 degrees, the dome will only start moving to sync with the mount's azimuth angle once the difference in azimuth angles is equal or exceeds 5 degrees.
Custom parking position is available for absolute/relative position domes.
For roll-off observatories, parking state reflects whether the roof is closed or open.
Developers need to subclass INDI::Dome to implement any driver for Domes within INDI.
- Note
- The code used calculate dome target AZ and ZD is written by Ferran Casarramona, and adapted from code from Markus Wildi. The transformations are based on the paper Matrix Method for Coordinates Transformation written by Toshimi Taki (http://www.asahi-net.or.jp/~zs3t-tk).
Definition at line 74 of file indidome.h.
Member Enumeration Documentation
◆ anonymous enum
| anonymous enum |
Definition at line 154 of file indidome.h.
◆ anonymous enum
| anonymous enum |
| Enumerator | |
|---|---|
| CONNECTION_NONE | |
| CONNECTION_SERIAL | Do not use any connection plugin |
| CONNECTION_TCP | For regular serial and bluetooth connections |
Definition at line 169 of file indidome.h.
◆ anonymous enum
|
protected |
| Enumerator | |
|---|---|
| ACTIVE_MOUNT | |
| ACTIVE_INPUT | |
| ACTIVE_OUTPUT | |
Definition at line 555 of file indidome.h.
◆ anonymous enum
|
protected |
| Enumerator | |
|---|---|
| SHUTTER_CLOSE_ON_PARK | |
| SHUTTER_OPEN_ON_UNPARK | |
Definition at line 567 of file indidome.h.
◆ anonymous enum
|
protected |
| Enumerator | |
|---|---|
| DM_OTA_SIDE_EAST | |
| DM_OTA_SIDE_WEST | |
| DM_OTA_SIDE_MOUNT | |
| DM_OTA_SIDE_HA | |
| DM_OTA_SIDE_IGNORE | |
Definition at line 581 of file indidome.h.
◆ DomeDirection
| Enumerator | |
|---|---|
| DOME_CW | |
| DOME_CCW | |
Definition at line 91 of file indidome.h.
◆ DomeMeasurements
Measurements necessary for dome-slit synchronization. All values are in meters. The displacements are measured from the true dome centre, and the dome is assumed spherical.
- Note
- : The mount centre is the point where RA and Dec. axis crosses, no matter the kind of mount. For example, for a fork mount this displacement is typically 0 if it's perfectly centred with RA axis.
| Enumerator | |
|---|---|
| DM_DOME_RADIUS | Dome RADIUS |
| DM_SHUTTER_WIDTH | Shutter width |
| DM_NORTH_DISPLACEMENT | Displacement to north of the mount center |
| DM_EAST_DISPLACEMENT | Displacement to east of the mount center |
| DM_UP_DISPLACEMENT | Up Displacement of the mount center |
| DM_OTA_OFFSET | Distance from the optical axis to the mount center |
Definition at line 81 of file indidome.h.
◆ DomeMotionCommand
| Enumerator | |
|---|---|
| MOTION_START | |
| MOTION_STOP | |
Definition at line 96 of file indidome.h.
◆ DomeParkData
Dome Parking data type enum
| Enumerator | |
|---|---|
| PARK_NONE | 2-state parking (Open or Closed only) |
| PARK_AZ | Parking via azimuth angle control |
| PARK_AZ_ENCODER | Parking via azimuth encoder control |
Definition at line 103 of file indidome.h.
◆ DomeState
| enum Dome::DomeState |
Dome status.
| Enumerator | |
|---|---|
| DOME_IDLE | Dome is idle |
| DOME_MOVING | Dome is in motion |
| DOME_SYNCED | Dome is synced |
| DOME_PARKING | Dome is parking |
| DOME_UNPARKING | Dome is unparking |
| DOME_PARKED | Dome is parked |
| DOME_UNPARKED | Dome is unparked |
| DOME_UNKNOWN | Dome state is known |
| DOME_ERROR | Dome has errors |
Definition at line 129 of file indidome.h.
◆ MountLockingPolicy
Mount Locking Policy
| Enumerator | |
|---|---|
| MOUNT_IGNORED | Mount is ignored. Dome can park or unpark irrespective of mount parking status |
| MOUNT_LOCKS | Mount Locks. Dome can park if mount is completely parked first. |
Definition at line 120 of file indidome.h.
◆ ShutterOperation
Shutter operation command.
| Enumerator | |
|---|---|
| SHUTTER_OPEN | Open Shutter |
| SHUTTER_CLOSE | Close Shutter |
Definition at line 113 of file indidome.h.
◆ ShutterState
Definition at line 145 of file indidome.h.
Constructor & Destructor Documentation
◆ Dome()
| Dome::Dome | ( | ) |
Definition at line 53 of file indidome.cpp.
◆ ~Dome()
|
virtual |
Definition at line 77 of file indidome.cpp.
Member Function Documentation
◆ Abort()
|
protectedvirtual |
Abort all dome motion.
- Returns
- True if abort is successful, false otherwise.
Reimplemented in AlpacaDome, BaaderDome, DDW, DomeScript, DomeSim, DomePro2, DragonLAIR, HakosRoof, Beaver, RigelDome, RollOff, RTIDome, ScopeDome, and UniversalROR.
Definition at line 2179 of file indidome.cpp.
◆ ActiveDevicesUpdated()
|
inlineprotectedvirtual |
Signal to concrete driver when Active Devices are updated.
Reimplemented in UniversalROR.
Definition at line 527 of file indidome.h.
◆ buttonHelper()
|
static |
Definition at line 1131 of file indidome.cpp.
◆ CanAbort()
|
inline |
- Returns
- True if dome support aborting motion
Definition at line 218 of file indidome.h.
◆ CanAbsMove()
|
inline |
- Returns
- True if dome has absolute position encoders.
Definition at line 226 of file indidome.h.
◆ CanPark()
|
inline |
- Returns
- True if dome can park.
Definition at line 242 of file indidome.h.
◆ CanRelMove()
|
inline |
- Returns
- True if dome has relative position encoders.
Definition at line 234 of file indidome.h.
◆ CanSync()
|
inline |
- Returns
- True if dome can sync.
Definition at line 250 of file indidome.h.
◆ CheckHorizon()
|
protected |
CheckHorizon Returns true if telescope points above horizon.
- Parameters
-
HA Hour angle dec Declination lat observer's latitude
- Returns
- True if telescope points above horizon, false otherwise.
Definition at line 1602 of file indidome.cpp.
◆ ControlShutter()
|
protectedvirtual |
Open or Close shutter.
- Parameters
-
operation Either open or close the shutter.
- Returns
- Return IPS_OK if shutter operation is complete. Return IPS_BUSY if shutter operation is in progress. Return IPS_ALERT if there is an error.
Reimplemented in AlpacaDome, BaaderDome, DDW, DomeScript, DomeSim, DomePro2, Beaver, RigelDome, RTIDome, and ScopeDome.
Definition at line 2254 of file indidome.cpp.
◆ Csc()
|
protected |
Definition at line 1592 of file indidome.cpp.
◆ GetAxis1Park()
|
protected |
- Returns
- Get current AZ parking position.
Definition at line 1977 of file indidome.cpp.
◆ GetAxis1ParkDefault()
|
protected |
- Returns
- Get default AZ parking position.
Definition at line 1982 of file indidome.cpp.
◆ GetDomeCapability()
|
inline |
GetDomeCapability returns the capability of the dome.
Definition at line 204 of file indidome.h.
◆ getDomeConnection()
| uint8_t Dome::getDomeConnection | ( | ) | const |
- Returns
- Get current Dome connection mode
Definition at line 2408 of file indidome.cpp.
◆ getDomeState()
|
inline |
Definition at line 285 of file indidome.h.
◆ getMountState()
| IPState Dome::getMountState | ( | ) | const |
Definition at line 1169 of file indidome.cpp.
◆ getShutterState()
|
inline |
Definition at line 291 of file indidome.h.
◆ GetShutterStatusString()
|
protected |
getShutterStatusString
- Parameters
-
status Status of shutter
- Returns
- Returns string representation of the shutter status
Definition at line 1697 of file indidome.cpp.
◆ GetTargetAz()
|
protected |
GetTargetAz.
- Parameters
-
Az Returns Azimuth required to the dome in order to center the shutter aperture with telescope Alt minAz Returns Minimum azimuth in order to avoid any dome interference to the full aperture of the telescope maxAz Returns Maximum azimuth in order to avoid any dome interference to the full aperture of the telescope
- Returns
- Returns false if it can't solve it due bad geometry of the observatory
The problem to get a dome azimuth given a telescope azimuth, altitude and geometry (telescope placement, mount geometry) can be seen as solve the intersection between the optical axis with the dome, that is, the intersection between a line and a sphere. To do that we need to calculate the optical axis line taking the centre of the dome as origin of coordinates. Returns false if it can't solve it due bad geometry of the observatory Returns:
- Parameters
-
Az : Azimuth required to the dome in order to center the shutter aperture with telescope minAz Minimum azimuth in order to avoid any dome interference to the full aperture of the telescope maxAz Maximum azimuth in order to avoid any dome interference to the full aperture of the telescope
Definition at line 1335 of file indidome.cpp.
◆ Handshake()
|
protectedvirtual |
perform handshake with device to check communication
Reimplemented in BaaderDome, DDW, DomePro2, Beaver, RigelDome, RTIDome, and ScopeDome.
Definition at line 2390 of file indidome.cpp.
◆ HasBacklash()
|
inline |
- Returns
- True if the dome supports backlash
Definition at line 274 of file indidome.h.
◆ HasShutter()
|
inline |
- Returns
- True if dome has controllable shutter door
Definition at line 258 of file indidome.h.
◆ HasVariableSpeed()
|
inline |
- Returns
- True if dome support multiple speeds
Definition at line 266 of file indidome.h.
◆ InitPark()
|
protected |
InitPark Loads parking data (stored in ~/.indi/ParkData.xml) that contains parking status and parking position. InitPark() should be called after successful connection to the dome on startup.
- Returns
- True if loading is successful and data is read, false otherwise. On success, you must call SetAzParkDefault() to set the default parking values. On failure, you must call SetAzParkDefault() to set the default parking values in addition to SetAzPark() to set the current parking position.
Definition at line 1770 of file indidome.cpp.
◆ initProperties()
|
overridevirtual |
Initialize properties initial state and value. The child class must implement this function.
- Returns
- True if initialization is successful, false otherwise.
Reimplemented from INDI::DefaultDevice.
Reimplemented in AlpacaDome, BaaderDome, DDW, DomeScript, DomeSim, DomePro2, DragonLAIR, HakosRoof, Beaver, RigelDome, RollOff, RTIDome, ScopeDome, and UniversalROR.
Definition at line 105 of file indidome.cpp.
◆ Intersection()
Intersection Calculate the intersection of a ray and a sphere. The line segment is defined from p1 to p2. The sphere is of radius r and centered at (0,0,0). From http://local.wasp.uwa.edu.au/~pbourke/geometry/sphereline/ There are potentially two points of intersection given by p := p1 + mu1 (p2 - p1) p := p1 + mu2 (p2 - p1)
- Parameters
-
p1 First point p2 Direction of the ray r RADIUS of sphere mu1 First point of potentional intersection. mu2 Second point of potentional intersection.
- Returns
- Returns FALSE if the ray doesn't intersect the sphere.
Definition at line 1533 of file indidome.cpp.
◆ ISGetProperties()
|
overridevirtual |
define the driver's properties to the client. Usually, only a minimum set of properties are defined to the client in this function if the device is in disconnected state. Those properties should be enough to enable the client to establish a connection to the device. In addition to CONNECT/DISCONNECT, such properties may include port name, IP address, etc. You should check if the device is already connected, and if this is true, then you must define the remainder of the the properties to the client in this function. Otherwise, the remainder of the driver's properties are defined to the client in updateProperties() function which is called when a client connects/disconnects from a device.
- Parameters
-
dev name of the device
- Note
- This function is called by the INDI framework, do not call it directly. See LX200 Generic driver for an example implementation
Reimplemented from INDI::DefaultDevice.
Reimplemented in AlpacaDome, DomeScript, DragonLAIR, and HakosRoof.
Definition at line 270 of file indidome.cpp.
◆ isLocked()
| bool Dome::isLocked | ( | ) |
isLocked, is the dome currently locked?
- Returns
- True if lock status equals true, and TelescopeClosedLockTP is Telescope Locks.
Definition at line 1123 of file indidome.cpp.
◆ ISNewNumber()
|
overridevirtual |
Process the client newNumber command.
- Note
- This function is called by the INDI framework, do not call it directly.
- Returns
- True if any property was successfully processed, false otherwise.
Reimplemented from INDI::DefaultDevice.
Reimplemented in AlpacaDome, DomeSim, DomePro2, HakosRoof, Beaver, RigelDome, RTIDome, and ScopeDome.
Definition at line 394 of file indidome.cpp.
◆ ISNewSwitch()
|
overridevirtual |
Process the client newSwitch command.
- Note
- This function is called by the INDI framework, do not call it directly.
- Returns
- True if any property was successfully processed, false otherwise.
Reimplemented from INDI::DefaultDevice.
Reimplemented in AlpacaDome, BaaderDome, DomeScript, DomePro2, DragonLAIR, HakosRoof, Beaver, RigelDome, RollOff, RTIDome, ScopeDome, and UniversalROR.
Definition at line 503 of file indidome.cpp.
◆ ISNewText()
|
overridevirtual |
Process the client newSwitch command.
- Note
- This function is called by the INDI framework, do not call it directly.
- Returns
- True if any property was successfully processed, false otherwise.
Reimplemented from INDI::DefaultDevice.
Reimplemented in AlpacaDome, DomeScript, DragonLAIR, HakosRoof, ScopeDome, and UniversalROR.
Definition at line 809 of file indidome.cpp.
◆ isParked()
|
protected |
isParked is dome currently parked?
- Returns
- True if parked, false otherwise.
Definition at line 1765 of file indidome.cpp.
◆ ISSnoopDevice()
|
overridevirtual |
Process a snoop event from INDI server. This function is called when a snooped property is updated in a snooped driver.
- Note
- This function is called by the INDI framework, do not call it directly.
- Returns
- True if any property was successfully processed, false otherwise.
Reimplemented from INDI::DefaultDevice.
Reimplemented in DragonLAIR, RollOff, and UniversalROR.
Definition at line 841 of file indidome.cpp.
◆ LoadParkData()
|
protected |
Definition at line 1884 of file indidome.cpp.
◆ Move()
|
protectedvirtual |
Move the Dome in a particular direction.
- Parameters
-
dir Direction of Dome, either DOME_CW or DOME_CCW.
- Returns
- Return IPS_OK if dome operation is complete. IPS_BUSY if operation is in progress. IPS_ALERT on error.
Reimplemented in AlpacaDome, DomeScript, DomeSim, DomePro2, DragonLAIR, HakosRoof, Beaver, RigelDome, RollOff, RTIDome, ScopeDome, and UniversalROR.
Definition at line 1999 of file indidome.cpp.
◆ MoveAbs()
|
protectedvirtual |
Move the Dome to an absolute azimuth.
- Parameters
-
az The new position of the Dome.
- Returns
- Return IPS_OK if motion is completed and Dome reached requested position. Return IPS_BUSY if Dome started motion to requested position and is in progress. Return IPS_ALERT if there is an error.
Reimplemented in AlpacaDome, BaaderDome, DDW, DomeScript, DomeSim, DomePro2, Beaver, RigelDome, RTIDome, and ScopeDome.
Definition at line 2107 of file indidome.cpp.
◆ MoveRel()
|
protectedvirtual |
Move the Dome to an relative position.
- Parameters
-
azDiff The relative azimuth angle to move. Positive degree is clock-wise direction. Negative degrees is counter clock-wise direction.
- Returns
- Return IPS_OK if motion is completed and Dome reached requested position. Return IPS_BUSY if Dome started motion to requested position and is in progress. Return IPS_ALERT if there is an error.
Reimplemented in AlpacaDome, BaaderDome, DomeSim, DomePro2, Beaver, RigelDome, RTIDome, and ScopeDome.
Definition at line 2039 of file indidome.cpp.
◆ OpticalCenter()
|
protected |
OpticalCenter This function calculates the distance from the optical axis to the Dome center.
- Parameters
-
MountCenter Distance from the Dome center to the point where mount axis crosses dOpticalAxis Distance from the mount center to the optical axis. Lat Latitude Ah Hour Angle (in hours) OP a 3D point from the optical center to the Dome center.
- Returns
- false in case of error.
Definition at line 1557 of file indidome.cpp.
◆ OpticalVector()
|
protected |
OpticalVector This function calculates a second point for determining the optical axis.
- Parameters
-
Az Azimuth Alt Altitude OV a 3D point that determines the optical line.
- Returns
- false in case of error.
Definition at line 1579 of file indidome.cpp.
◆ Park()
|
protectedvirtual |
Goto Park Position. The park position is an absolute azimuth value.
- Returns
- Return IPS_OK if motion is completed and Dome reached park position. Return IPS_BUSY if Dome started motion to park requested position and is in progress. Return -IPS_ALERT if there is an error.
Reimplemented in AlpacaDome, BaaderDome, DDW, DomeScript, DomeSim, DomePro2, DragonLAIR, HakosRoof, Beaver, RigelDome, RollOff, RTIDome, ScopeDome, and UniversalROR.
Definition at line 2295 of file indidome.cpp.
◆ saveConfigItems()
|
overrideprotectedvirtual |
saveConfigItems Saves the Device Port and Dome Presets in the configuration file
- Parameters
-
fp pointer to configuration file
- Returns
- true if successful, false otherwise.
Reimplemented from INDI::DefaultDevice.
Reimplemented in AlpacaDome, BaaderDome, DDW, DomeScript, DomeSim, DomePro2, DragonLAIR, HakosRoof, Beaver, RollOff, ScopeDome, and UniversalROR.
Definition at line 1083 of file indidome.cpp.
◆ Sec()
|
protected |
Definition at line 1597 of file indidome.cpp.
◆ SetAxis1Park()
|
protected |
SetRAPark Set current AZ parking position. The data park file (stored in ~/.indi/ParkData.xml) is updated in the process.
- Parameters
-
value current Axis 1 value (AZ either in angles or encoder values as specified by the DomeParkData type).
Definition at line 1987 of file indidome.cpp.
◆ SetAxis1ParkDefault()
|
protected |
SetAxis1Park Set default AZ parking position.
- Parameters
-
value Default Axis 1 value (AZ either in angles or encoder values as specified by the DomeParkData type).
Definition at line 1994 of file indidome.cpp.
◆ SetBacklash()
|
protectedvirtual |
SetBacklash Set the dome backlash compensation value.
- Parameters
-
steps value in absolute steps to compensate
- Returns
- True if successful, false otherwise.
Definition at line 1061 of file indidome.cpp.
◆ SetBacklashEnabled()
|
protectedvirtual |
SetBacklashEnabled Enables or disables the dome backlash compensation.
- Parameters
-
enable flag to enable or disable backlash compensation
- Returns
- True if successful, false otherwise.
Definition at line 1071 of file indidome.cpp.
◆ SetCurrentPark()
|
protectedvirtual |
SetCurrentPark Set current coordinates/encoders value as the desired parking position.
- Note
- This function performs no action unless subclassed by the child class if required.
Reimplemented in AlpacaDome, BaaderDome, DDW, DomeSim, DomePro2, Beaver, RigelDome, RTIDome, and ScopeDome.
Definition at line 2378 of file indidome.cpp.
◆ SetDefaultPark()
|
protectedvirtual |
SetDefaultPark Set default coordinates/encoders value as the desired parking position.
- Note
- This function performs no action unless subclassed by the child class if required.
Reimplemented in AlpacaDome, BaaderDome, DDW, DomeSim, DomePro2, Beaver, RigelDome, RTIDome, and ScopeDome.
Definition at line 2384 of file indidome.cpp.
◆ SetDomeCapability()
| void Dome::SetDomeCapability | ( | uint32_t | cap | ) |
SetDomeCapability set the dome capabilities. All capabilities must be initialized.
- Parameters
-
cap pointer to dome capability
Definition at line 1689 of file indidome.cpp.
◆ setDomeConnection()
| void Dome::setDomeConnection | ( | const uint8_t & | value | ) |
setDomeConnection Set Dome connection mode. Child class should call this in the constructor before Dome registers any connection interfaces
- Parameters
-
value ORed combination of DomeConnection values.
Definition at line 2413 of file indidome.cpp.
◆ setDomeState()
| void Dome::setDomeState | ( | const DomeState & | value | ) |
Definition at line 1217 of file indidome.cpp.
◆ SetParkDataType()
|
protected |
setParkDataType Sets the type of parking data stored in the park data file and presented to the user.
- Parameters
-
type parking data type. If PARK_NONE then no properties will be presented to the user for custom parking position.
Definition at line 1715 of file indidome.cpp.
◆ SetParked()
|
protected |
SetParked Change the mount parking status. The data park file (stored in ~/.indi/ParkData.xml) is updated in the process.
- Parameters
-
isparked set to true if parked, false otherwise.
Definition at line 1759 of file indidome.cpp.
◆ setShutterState()
| void Dome::setShutterState | ( | const ShutterState & | value | ) |
Definition at line 1177 of file indidome.cpp.
◆ SetSpeed()
|
protectedvirtual |
SetSpeed Set Dome speed. This does not initiate motion, it sets the speed for the next motion command. If motion is in progress, then change speed accordingly.
- Parameters
-
rpm Dome speed (RPM)
- Returns
- true if successful, false otherwise
Reimplemented in AlpacaDome.
Definition at line 2233 of file indidome.cpp.
◆ Sync()
|
protectedvirtual |
Sync sets the dome current azimuth as the supplied azimuth position.
- Returns
- True if sync is successful, false otherwise.
Reimplemented in AlpacaDome, DomePro2, RigelDome, and RTIDome.
Definition at line 2172 of file indidome.cpp.
◆ UnPark()
|
protectedvirtual |
UnPark dome. The action of the Unpark command is dome specific, but it may include opening the shutter and moving to home position. When UnPark() is successful The observatory should be in a ready state to utilize the mount to perform observations.
- Returns
- Return IPS_OK if motion is completed and Dome is unparked. Return IPS_BUSY if Dome unparking is in progress. Return -IPS_ALERT if there is an error.
Reimplemented in AlpacaDome, BaaderDome, DDW, DomeScript, DomeSim, DomePro2, DragonLAIR, HakosRoof, Beaver, RigelDome, RollOff, RTIDome, ScopeDome, and UniversalROR.
Definition at line 2349 of file indidome.cpp.
◆ UpdateAutoSync()
|
protectedvirtual |
UpdateAutoSync This function calculates the target dome azimuth from the mount's target coordinates given the dome parameters. If the difference between the dome's and mount's azimuth angles exceeds the AutoSync threshold, the dome will be commanded to sync to the mount azimuth position.
Definition at line 1642 of file indidome.cpp.
◆ UpdateMountCoords()
|
protected |
updateCoords updates the horizontal coordinates (Az & Alt) of the mount from the snooped RA, DEC and observer's location.
Definition at line 1614 of file indidome.cpp.
◆ updateProperties()
|
overridevirtual |
updateProperties is called whenever there is a change in the CONNECTION status of the driver. This will enable the driver to react to changes of switching ON/OFF a device. For example, a driver may only define a set of properties after a device is connected, but not before.
- Returns
- True if update is successful, false otherwise.
Reimplemented from INDI::DefaultDevice.
Reimplemented in AlpacaDome, BaaderDome, DDW, DomeScript, DomeSim, DomePro2, DragonLAIR, HakosRoof, Beaver, RigelDome, RollOff, RTIDome, ScopeDome, and UniversalROR.
Definition at line 284 of file indidome.cpp.
◆ WriteParkData()
|
protected |
Definition at line 1915 of file indidome.cpp.
Member Data Documentation
◆ AbortSP
|
protected |
Definition at line 540 of file indidome.h.
◆ ActiveDeviceTP
|
protected |
Definition at line 554 of file indidome.h.
◆ capability
|
protected |
Definition at line 599 of file indidome.h.
◆ DomeAbsPosNP
|
protected |
Definition at line 536 of file indidome.h.
◆ DomeAutoSyncSP
|
protected |
Definition at line 591 of file indidome.h.
◆ DomeBacklashNP
|
protected |
Definition at line 597 of file indidome.h.
◆ DomeBacklashSP
|
protected |
Definition at line 594 of file indidome.h.
◆ []
| enum { ... } INDI::Dome::DomeConnection |
◆ DomeMeasurementsNP
|
protected |
Definition at line 576 of file indidome.h.
◆ DomeMotionSP
|
protected |
Definition at line 534 of file indidome.h.
◆ DomeParamNP
|
protected |
Definition at line 542 of file indidome.h.
◆ DomeRelPosNP
|
protected |
Definition at line 538 of file indidome.h.
◆ DomeShutterSP
|
protected |
Definition at line 546 of file indidome.h.
◆ DomeSpeedNP
|
protected |
Definition at line 532 of file indidome.h.
◆ DomeSyncNP
|
protected |
Definition at line 544 of file indidome.h.
◆ HaveLatLong
|
protected |
Definition at line 618 of file indidome.h.
◆ HaveRaDec
|
protected |
Definition at line 624 of file indidome.h.
◆ m_DomeState
|
protected |
Definition at line 611 of file indidome.h.
◆ m_MountState
|
protected |
Definition at line 613 of file indidome.h.
◆ m_ShutterState
|
protected |
Definition at line 612 of file indidome.h.
◆ mountEquatorialCoords
|
protected |
Definition at line 622 of file indidome.h.
◆ mountHoriztonalCoords
|
protected |
Definition at line 621 of file indidome.h.
◆ mountOTASide
|
protected |
Definition at line 590 of file indidome.h.
◆ MountPolicySP
|
protected |
Definition at line 563 of file indidome.h.
◆ observer
|
protected |
Definition at line 616 of file indidome.h.
◆ OTASideSP
|
protected |
Definition at line 578 of file indidome.h.
◆ parkDataType
|
protected |
Definition at line 600 of file indidome.h.
◆ ParkOptionSP
|
protected |
Definition at line 552 of file indidome.h.
◆ ParkPositionNP
|
protected |
Definition at line 550 of file indidome.h.
◆ ParkSP
|
protected |
Definition at line 548 of file indidome.h.
◆ PortFD
|
protected |
Definition at line 605 of file indidome.h.
◆ PresetGotoSP
|
protected |
Definition at line 574 of file indidome.h.
◆ PresetNP
|
protected |
Definition at line 573 of file indidome.h.
◆ prev_alt
|
protected |
Definition at line 602 of file indidome.h.
◆ prev_az
|
protected |
Definition at line 602 of file indidome.h.
◆ prev_dec
|
protected |
Definition at line 602 of file indidome.h.
◆ prev_ra
|
protected |
Definition at line 602 of file indidome.h.
◆ serialConnection
|
protected |
Definition at line 607 of file indidome.h.
◆ ShutterParkPolicySP
|
protected |
Definition at line 566 of file indidome.h.
◆ tcpConnection
|
protected |
Definition at line 608 of file indidome.h.
The documentation for this class was generated from the following files:
