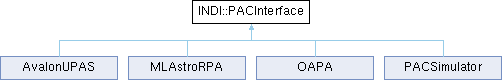
#include <indipacinterface.h>
Public Types | |
| enum | { MANUAL_AZ , MANUAL_ALT } |
| enum | { POSITION_AZ , POSITION_ALT } |
| enum | { PAC_HAS_SPEED = 1 << 0 , PAC_CAN_REVERSE = 1 << 1 , PAC_HAS_POSITION = 1 << 2 , PAC_CAN_HOME = 1 << 3 , PAC_HAS_BACKLASH = 1 << 4 , PAC_CAN_SYNC = 1 << 5 } |
| PAC capability flags passed to SetCapability(). More... | |
Public Member Functions | |
| uint32_t | GetCapability () const |
| void | SetCapability (uint32_t cap) |
| SetCapability sets the PAC device capabilities. Call this in the driver constructor. | |
| bool | HasSpeed () |
| bool | CanReverse () |
| bool | HasPosition () |
| bool | CanHome () |
| bool | HasBacklash () |
| bool | CanSync () |
Public Attributes | |
| enum INDI::PACInterface:: { ... } | PACCapability |
| PAC capability flags passed to SetCapability(). | |
Protected Types | |
| enum | { HOME_SET , HOME_GO , HOME_RESET } |
| enum | { SYNC_AZ , SYNC_ALT } |
| enum | { BACKLASH_AZ , BACKLASH_ALT } |
Protected Member Functions | |
| PACInterface (DefaultDevice *device) | |
| virtual | ~PACInterface ()=default |
| virtual IPState | MoveAZ (double degrees) |
| Move the azimuth axis by the given number of degrees. | |
| virtual IPState | MoveALT (double degrees) |
| MoveALT Move the altitude axis by the given number of degrees. | |
| virtual IPState | MoveBoth (double azDegrees, double altDegrees) |
| MoveBoth Move both axes in a single coordinated operation. | |
| virtual bool | AbortMotion () |
| AbortMotion Abort all axis motion immediately. | |
| virtual bool | SetPACSpeed (uint16_t speed) |
| SetPACSpeed Set the motor speed used for axis movements. | |
| virtual bool | ReverseAZ (bool enabled) |
| ReverseAZ Reverse the direction of azimuth axis movement. | |
| virtual bool | ReverseALT (bool enabled) |
| ReverseALT Reverse the direction of altitude axis movement. | |
| virtual bool | SetHome () |
| SetHome Mark the current position as the home (zero) reference. | |
| virtual IPState | GoHome () |
| GoHome Slew both axes back to the home (0, 0) position. | |
| virtual bool | ResetHome () |
| ResetHome Clear the stored home reference without moving. | |
| virtual bool | SyncAZ (double degrees) |
| SyncAZ Sync the azimuth position reference to the given value without moving. | |
| virtual bool | SyncALT (double degrees) |
| SyncALT Sync the altitude position reference to the given value without moving. | |
| virtual bool | SetBacklashEnabled (bool enabled) |
| SetBacklashEnabled Enable or disable hardware backlash compensation. | |
| virtual bool | SetBacklashAZ (int32_t steps) |
| SetBacklashAZ Set the azimuth axis backlash compensation value in steps. | |
| virtual bool | SetBacklashALT (int32_t steps) |
| SetBacklashALT Set the altitude axis backlash compensation value in steps. | |
| void | initProperties (const char *group) |
| initProperties Initialize PAC properties. Call this from your driver's initProperties(). | |
| bool | updateProperties () |
| updateProperties Define or delete properties based on connection state. Call this from your driver's updateProperties(). | |
| bool | processSwitch (const char *dev, const char *name, ISState *states, char *names[], int n) |
| Process PAC switch properties. | |
| bool | processNumber (const char *dev, const char *name, double values[], char *names[], int n) |
| Process PAC number properties. | |
| bool | saveConfigItems (FILE *fp) |
| saveConfigItems Save PAC interface properties to config file. Call this from your driver's saveConfigItems(). | |
Protected Attributes | |
| INDI::PropertyNumber | ManualAdjustmentNP {2} |
| INDI::PropertySwitch | AbortSP {1} |
| INDI::PropertyNumber | PositionNP {2} |
| INDI::PropertyNumber | SpeedNP {1} |
| INDI::PropertySwitch | AZReverseSP {2} |
| INDI::PropertySwitch | ALTReverseSP {2} |
| INDI::PropertySwitch | HomeSP {3} |
| INDI::PropertyNumber | SyncNP {2} |
| INDI::PropertySwitch | BacklashSP {2} |
| INDI::PropertyNumber | BacklashNP {2} |
Detailed Description
Definition at line 62 of file indipacinterface.h.
Member Enumeration Documentation
◆ anonymous enum
| anonymous enum |
Indices for the ManualAdjustmentNP number property.
| Enumerator | |
|---|---|
| MANUAL_AZ | Azimuth step in degrees: positive = East, negative = West. |
| MANUAL_ALT | Altitude step in degrees: positive = North, negative = South. |
Definition at line 66 of file indipacinterface.h.
◆ anonymous enum
| anonymous enum |
Indices for the PositionNP number property.
| Enumerator | |
|---|---|
| POSITION_AZ | Current azimuth position in degrees. |
| POSITION_ALT | Current altitude position in degrees. |
Definition at line 73 of file indipacinterface.h.
◆ anonymous enum
| anonymous enum |
PAC capability flags passed to SetCapability().
Definition at line 82 of file indipacinterface.h.
◆ anonymous enum
|
protected |
| Enumerator | |
|---|---|
| HOME_SET | |
| HOME_GO | |
| HOME_RESET | |
Definition at line 399 of file indipacinterface.h.
◆ anonymous enum
|
protected |
| Enumerator | |
|---|---|
| SYNC_AZ | |
| SYNC_ALT | |
Definition at line 408 of file indipacinterface.h.
◆ anonymous enum
|
protected |
| Enumerator | |
|---|---|
| BACKLASH_AZ | |
| BACKLASH_ALT | |
Definition at line 421 of file indipacinterface.h.
Constructor & Destructor Documentation
◆ PACInterface()
|
explicitprotected |
Definition at line 31 of file indipacinterface.cpp.
◆ ~PACInterface()
|
protectedvirtualdefault |
Member Function Documentation
◆ AbortMotion()
|
protectedvirtual |
AbortMotion Abort all axis motion immediately.
The default implementation logs an error and returns false. Drivers that support hardware abort should override this method.
- Returns
- True if motion was successfully aborted, false otherwise.
Reimplemented in AvalonUPAS, MLAstroRPA, OAPA, and PACSimulator.
Definition at line 385 of file indipacinterface.cpp.
◆ CanHome()
|
inline |
- Returns
- True if the device supports Set/Return/Reset home.
Definition at line 126 of file indipacinterface.h.
◆ CanReverse()
|
inline |
- Returns
- True if the device supports reversing axis direction.
Definition at line 114 of file indipacinterface.h.
◆ CanSync()
|
inline |
- Returns
- True if the device can sync AZ/ALT position reference.
Definition at line 138 of file indipacinterface.h.
◆ GetCapability()
|
inline |
- Returns
- Current capability bitmask.
Definition at line 93 of file indipacinterface.h.
◆ GoHome()
|
protectedvirtual |
GoHome Slew both axes back to the home (0, 0) position.
Only called when PAC_CAN_HOME is set. Default returns IPS_ALERT.
- Returns
- IPS_OK if completed immediately, IPS_BUSY if in progress, IPS_ALERT on error.
Reimplemented in MLAstroRPA.
Definition at line 423 of file indipacinterface.cpp.
◆ HasBacklash()
|
inline |
- Returns
- True if the device supports backlash compensation.
Definition at line 132 of file indipacinterface.h.
◆ HasPosition()
|
inline |
- Returns
- True if the device can report its current axis position.
Definition at line 120 of file indipacinterface.h.
◆ HasSpeed()
|
inline |
- Returns
- True if the device supports variable speed.
Definition at line 108 of file indipacinterface.h.
◆ initProperties()
|
protected |
initProperties Initialize PAC properties. Call this from your driver's initProperties().
- Parameters
-
group Group or tab name for the properties.
Definition at line 36 of file indipacinterface.cpp.
◆ MoveALT()
|
protectedvirtual |
MoveALT Move the altitude axis by the given number of degrees.
Sign convention: positive = North (increase altitude), negative = South.
The default implementation returns IPS_ALERT. Drivers with motorised altitude adjustment must override this method.
- Parameters
-
degrees Signed step size in degrees.
- Returns
- IPS_OK if completed immediately, IPS_BUSY if in progress, IPS_ALERT on error.
Reimplemented in AvalonUPAS, MLAstroRPA, OAPA, and PACSimulator.
Definition at line 368 of file indipacinterface.cpp.
◆ MoveAZ()
|
protectedvirtual |
Move the azimuth axis by the given number of degrees.
Sign convention: positive = East, negative = West.
The default implementation returns IPS_ALERT. Drivers with motorised azimuth adjustment must override this method.
- Parameters
-
degrees Signed step size in degrees.
- Returns
- IPS_OK if completed immediately, IPS_BUSY if in progress, IPS_ALERT on error.
Reimplemented in AvalonUPAS, MLAstroRPA, OAPA, and PACSimulator.
Definition at line 362 of file indipacinterface.cpp.
◆ MoveBoth()
|
protectedvirtual |
MoveBoth Move both axes in a single coordinated operation.
Called by processNumber() when both azStep and altStep are non-zero. The default implementation calls MoveAZ() followed by MoveALT(), preserving backward-compatible behaviour for any driver that does not override this method.
Drivers that can do better should override this:
- Hardware with native dual-axis commands (e.g. GRBL) can pack both axes into a single serial command for truly simultaneous motion.
- Hardware with shared angle registers that must sequence internally (e.g. MLAstro RPA) can send one chained command and let the device handle the AZ→ALT sequence on its own.
- Parameters
-
azDegrees Signed azimuth step in degrees (+East / −West). altDegrees Signed altitude step in degrees (+North / −South).
- Returns
- IPS_OK if completed immediately, IPS_BUSY if in progress, IPS_ALERT on error.
Reimplemented in AvalonUPAS, MLAstroRPA, and OAPA.
Definition at line 374 of file indipacinterface.cpp.
◆ processNumber()
|
protected |
Process PAC number properties.
Definition at line 262 of file indipacinterface.cpp.
◆ processSwitch()
|
protected |
Process PAC switch properties.
Definition at line 151 of file indipacinterface.cpp.
◆ ResetHome()
|
protectedvirtual |
ResetHome Clear the stored home reference without moving.
Only called when PAC_CAN_HOME is set. Default implementation returns false.
- Returns
- True if successful, false otherwise.
Reimplemented in MLAstroRPA.
Definition at line 430 of file indipacinterface.cpp.
◆ ReverseALT()
|
protectedvirtual |
ReverseALT Reverse the direction of altitude axis movement.
Only called when PAC_CAN_REVERSE capability is set.
- Parameters
-
enabled True to reverse, false to restore normal direction.
- Returns
- True if successful, false otherwise.
Reimplemented in AvalonUPAS, MLAstroRPA, OAPA, and PACSimulator.
Definition at line 408 of file indipacinterface.cpp.
◆ ReverseAZ()
|
protectedvirtual |
ReverseAZ Reverse the direction of azimuth axis movement.
Only called when PAC_CAN_REVERSE capability is set.
- Parameters
-
enabled True to reverse, false to restore normal direction.
- Returns
- True if successful, false otherwise.
Reimplemented in AvalonUPAS, MLAstroRPA, OAPA, and PACSimulator.
Definition at line 400 of file indipacinterface.cpp.
◆ saveConfigItems()
|
protected |
saveConfigItems Save PAC interface properties to config file. Call this from your driver's saveConfigItems().
- Parameters
-
fp Pointer to the open config file.
- Returns
- True on success.
Definition at line 337 of file indipacinterface.cpp.
◆ SetBacklashALT()
|
protectedvirtual |
SetBacklashALT Set the altitude axis backlash compensation value in steps.
Only called when PAC_HAS_BACKLASH is set. Default returns false.
- Parameters
-
steps Number of motor steps used to compensate altitude backlash.
- Returns
- True if successful, false otherwise.
Reimplemented in MLAstroRPA.
Definition at line 469 of file indipacinterface.cpp.
◆ SetBacklashAZ()
|
protectedvirtual |
SetBacklashAZ Set the azimuth axis backlash compensation value in steps.
Only called when PAC_HAS_BACKLASH is set. Default returns false.
- Parameters
-
steps Number of motor steps used to compensate azimuth backlash.
- Returns
- True if successful, false otherwise.
Reimplemented in MLAstroRPA.
Definition at line 461 of file indipacinterface.cpp.
◆ SetBacklashEnabled()
|
protectedvirtual |
SetBacklashEnabled Enable or disable hardware backlash compensation.
Only called when PAC_HAS_BACKLASH is set. Default returns false.
- Parameters
-
enabled True to enable backlash compensation, false to disable.
- Returns
- True if successful, false otherwise.
Reimplemented in MLAstroRPA.
Definition at line 453 of file indipacinterface.cpp.
◆ SetCapability()
|
inline |
SetCapability sets the PAC device capabilities. Call this in the driver constructor.
- Parameters
-
cap Bitmask of PAC_HAS_SPEED, PAC_CAN_REVERSE, and/or PAC_HAS_POSITION.
Definition at line 102 of file indipacinterface.h.
◆ SetHome()
|
protectedvirtual |
SetHome Mark the current position as the home (zero) reference.
Only called when PAC_CAN_HOME is set. Default implementation returns false.
- Returns
- True if successful, false otherwise.
Reimplemented in MLAstroRPA.
Definition at line 416 of file indipacinterface.cpp.
◆ SetPACSpeed()
|
protectedvirtual |
SetPACSpeed Set the motor speed used for axis movements.
Only called when PAC_HAS_SPEED capability is set. The default implementation logs an error and returns false; drivers with variable-speed hardware must override.
- Parameters
-
speed Speed value (range defined by the driver, default 1–10).
- Returns
- True if the speed was applied successfully, false otherwise.
Reimplemented in AvalonUPAS, MLAstroRPA, and PACSimulator.
Definition at line 392 of file indipacinterface.cpp.
◆ SyncALT()
|
protectedvirtual |
SyncALT Sync the altitude position reference to the given value without moving.
Only called when PAC_CAN_SYNC is set. Default returns false.
- Parameters
-
degrees Desired current altitude reading in degrees.
- Returns
- True if successful, false otherwise.
Reimplemented in MLAstroRPA.
Definition at line 445 of file indipacinterface.cpp.
◆ SyncAZ()
|
protectedvirtual |
SyncAZ Sync the azimuth position reference to the given value without moving.
Only called when PAC_CAN_SYNC is set. Default returns false.
- Parameters
-
degrees Desired current azimuth reading in degrees.
- Returns
- True if successful, false otherwise.
Reimplemented in MLAstroRPA.
Definition at line 437 of file indipacinterface.cpp.
◆ updateProperties()
|
protected |
updateProperties Define or delete properties based on connection state. Call this from your driver's updateProperties().
- Returns
- true on success.
Definition at line 99 of file indipacinterface.cpp.
Member Data Documentation
◆ AbortSP
|
protected |
Abort motion property. Pressing Abort calls AbortMotion() and resets ManualAdjustmentNP and PositionNP to IPS_IDLE.
Definition at line 369 of file indipacinterface.h.
◆ ALTReverseSP
|
protected |
Altitude axis reverse switch. Only defined when PAC_CAN_REVERSE is set.
Definition at line 392 of file indipacinterface.h.
◆ AZReverseSP
|
protected |
Azimuth axis reverse switch. Only defined when PAC_CAN_REVERSE is set.
Definition at line 387 of file indipacinterface.h.
◆ BacklashNP
|
protected |
Backlash compensation steps per axis. Only defined when PAC_HAS_BACKLASH is set. Element [BACKLASH_AZ] : azimuth backlash in motor steps. Element [BACKLASH_ALT]: altitude backlash in motor steps.
Definition at line 420 of file indipacinterface.h.
◆ BacklashSP
|
protected |
Backlash enable/disable switch. Only defined when PAC_HAS_BACKLASH is set.
Definition at line 413 of file indipacinterface.h.
◆ HomeSP
|
protected |
Home management switch. Only defined when PAC_CAN_HOME is set. Elements: [HOME_SET] Set home, [HOME_GO] Return to home, [HOME_RESET] Reset home.
Definition at line 398 of file indipacinterface.h.
◆ ManualAdjustmentNP
|
protected |
Manual adjustment property. Element [MANUAL_AZ] : azimuth step in degrees (+East / −West). Element [MANUAL_ALT] : altitude step in degrees (+North / −South). Writing a non-zero value to either element immediately triggers the corresponding move.
State reflects overall motion: IPS_BUSY – one or both axes still moving IPS_ALERT – one or both axes encountered an error IPS_OK – both axes completed successfully
Definition at line 363 of file indipacinterface.h.
◆ []
| enum { ... } INDI::PACInterface::PACCapability |
PAC capability flags passed to SetCapability().
◆ PositionNP
|
protected |
Current axis position in degrees. Only defined when PAC_HAS_POSITION is set. Drivers should update this property periodically (e.g. from TimerHit).
Definition at line 375 of file indipacinterface.h.
◆ SpeedNP
|
protected |
Motor speed. Only defined when PAC_HAS_SPEED capability is set. Default range 1–10; drivers may adjust min/max/step in their initProperties() after calling PACI::initProperties().
Definition at line 382 of file indipacinterface.h.
◆ SyncNP
|
protected |
Sync position numbers. Only defined when PAC_CAN_SYNC is set. Writing a value syncs that axis position reference without moving. Element [SYNC_AZ] : new azimuth reference in degrees. Element [SYNC_ALT]: new altitude reference in degrees.
Definition at line 407 of file indipacinterface.h.
The documentation for this class was generated from the following files:
