The MLAstroRPA class drives the MLAstro Robotic Polar Alignment controller via its ESP32-based serial protocol. More...
#include <mlastro_rpa.h>
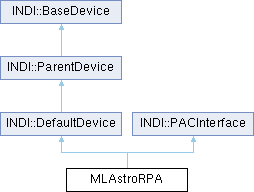
Public Member Functions | |
| MLAstroRPA () | |
| Constructor. | |
| virtual | ~MLAstroRPA () override=default |
| const char * | getDefaultName () override |
| Basic device info. | |
| bool | ISNewNumber (const char *dev, const char *name, double values[], char *names[], int n) override |
| ISNewNumber. | |
| bool | ISNewSwitch (const char *dev, const char *name, ISState *states, char *names[], int n) override |
| ISNewSwitch. | |
| bool | ISNewText (const char *dev, const char *name, char *texts[], char *names[], int n) override |
| ISNewText. | |
 Public Member Functions inherited from INDI::DefaultDevice | |
| DefaultDevice () | |
| virtual | ~DefaultDevice () override=default |
| void | addAuxControls () |
| Add Debug, Simulation, and Configuration options to the driver. | |
| void | addDebugControl () |
| Add Debug control to the driver. | |
| void | addSimulationControl () |
| Add Simulation control to the driver. | |
| void | addConfigurationControl () |
| Add Configuration control to the driver. | |
| void | addPollPeriodControl () |
| Add Polling period control to the driver. | |
| void | addNicknameControl () |
| Add Nickname text property to the driver. | |
| void | resetProperties () |
| Set all properties to IDLE state. | |
| void | defineNumber (INumberVectorProperty *nvp) |
| Define number vector to client & register it. Alternatively, IDDefNumber can be used but the property will not get registered and the driver will not be able to save configuration files. | |
| void | defineProperty (INumberVectorProperty *property) |
| void | defineText (ITextVectorProperty *tvp) |
| Define text vector to client & register it. Alternatively, IDDefText can be used but the property will not get registered and the driver will not be able to save configuration files. | |
| void | defineProperty (ITextVectorProperty *property) |
| void | defineSwitch (ISwitchVectorProperty *svp) |
| Define switch vector to client & register it. Alternatively, IDDefswitch can be used but the property will not get registered and the driver will not be able to save configuration files. | |
| void | defineProperty (ISwitchVectorProperty *property) |
| void | defineLight (ILightVectorProperty *lvp) |
| Define light vector to client & register it. Alternatively, IDDeflight can be used but the property will not get registered and the driver will not be able to save configuration files. | |
| void | defineProperty (ILightVectorProperty *property) |
| void | defineBLOB (IBLOBVectorProperty *bvp) |
| Define BLOB vector to client & register it. Alternatively, IDDefBLOB can be used but the property will not get registered and the driver will not be able to save configuration files. | |
| void | defineProperty (IBLOBVectorProperty *property) |
| void | defineProperty (INDI::Property &property) |
| virtual bool | deleteProperty (const char *propertyName) |
| Delete a property and unregister it. It will also be deleted from all clients. | |
| bool | deleteProperty (INDI::Property &property) |
| deleteProperty Delete a property and unregister it. It will also be deleted from all clients. | |
| virtual void | setConnected (bool status, IPState state=IPS_OK, const char *msg=nullptr) |
| Set connection switch status in the client. | |
| int | SetTimer (uint32_t ms) |
| Set a timer to call the function TimerHit after ms milliseconds. | |
| void | RemoveTimer (int id) |
| Remove timer added with SetTimer. | |
| virtual const char * | getDriverExec () |
| virtual const char * | getDriverName () |
| void | setVersion (uint16_t vMajor, uint16_t vMinor) |
| Set driver version information to be defined in DRIVER_INFO property as vMajor.vMinor. | |
| uint16_t | getMajorVersion () const |
| uint16_t | getMinorVersion () const |
| virtual void | ISGetProperties (const char *dev) |
| define the driver's properties to the client. Usually, only a minimum set of properties are defined to the client in this function if the device is in disconnected state. Those properties should be enough to enable the client to establish a connection to the device. In addition to CONNECT/DISCONNECT, such properties may include port name, IP address, etc. You should check if the device is already connected, and if this is true, then you must define the remainder of the the properties to the client in this function. Otherwise, the remainder of the driver's properties are defined to the client in updateProperties() function which is called when a client connects/disconnects from a device. | |
| virtual bool | ISNewBLOB (const char *dev, const char *name, int sizes[], int blobsizes[], char *blobs[], char *formats[], char *names[], int n) |
| Process the client newBLOB command. | |
| virtual bool | ISSnoopDevice (XMLEle *root) |
| Process a snoop event from INDI server. This function is called when a snooped property is updated in a snooped driver. | |
| bool | ISNewProperty (INDI::Property &property, const std::string &elementName, const std::any &value) |
| Generic convenience function to update a property element as if by client request, simulating an ISNew... call. | |
| template<typename PropertyType , typename ValueType > | |
| bool | updateProperty (PropertyType &property, ValueType *values, char *names[], int n, std::function< bool()> updater, bool saveConfig=false) |
| Generic helper function to update an INDI property based on an external operation. | |
| uint32_t | getDriverInterface () const |
| void | setDriverInterface (uint32_t value) |
| setInterface Set driver interface. By default the driver interface is set to GENERAL_DEVICE. You may send an ORed list of DeviceInterface values. | |
| void | watchDevice (const char *deviceName, const std::function< void(INDI::BaseDevice)> &callback) |
| Add a device to the watch list. | |
| Public Member Functions inherited from INDI::ParentDevice | |
| ParentDevice (Type type) | |
| ~ParentDevice () | |
| ParentDevice (ParentDevice &&other)=default | |
| ParentDevice & | operator= (ParentDevice &&other)=default |
| Public Member Functions inherited from INDI::BaseDevice | |
| BaseDevice () | |
| virtual | ~BaseDevice () |
| void | registerProperty (const INDI::Property &property) |
| Register the property to be able to observe and update. | |
| void | registerProperty (const INDI::Property &property, INDI_PROPERTY_TYPE type) |
| int | removeProperty (const char *name, char *errmsg) |
| Remove a property. | |
| void | watchProperty (const char *name, const std::function< void(INDI::Property)> &callback, WATCH watch=WATCH_NEW) |
| Call the callback function if property is available. | |
| Property | getProperty (const char *name, INDI_PROPERTY_TYPE type=INDI_UNKNOWN) const |
| Return a property and its type given its name. | |
| Properties | getProperties () |
| Return a list of all properties in the device. | |
| const Properties | getProperties () const |
| INDI::PropertyNumber | getNumber (const char *name) const |
| INDI::PropertyText | getText (const char *name) const |
| INDI::PropertySwitch | getSwitch (const char *name) const |
| INDI::PropertyLight | getLight (const char *name) const |
| INDI::PropertyBlob | getBLOB (const char *name) const |
| IPState | getPropertyState (const char *name) const |
| IPerm | getPropertyPermission (const char *name) const |
| void * | getRawProperty (const char *name, INDI_PROPERTY_TYPE type=INDI_UNKNOWN) const |
| Return a property and its type given its name. | |
| void | addMessage (const std::string &msg) |
| Add message to the driver's message queue. | |
| void | checkMessage (XMLEle *root) |
| void | doMessage (XMLEle *msg) |
| const std::string & | messageQueue (size_t index) const |
| const std::string & | lastMessage () const |
| bool | isValid () const |
| bool | isSameDevice (const BaseDevice &other) const |
| bool | isConnected () const |
| void | attach () |
| indicates that the device is ready | |
| void | detach () |
| indicates that the device is being removed | |
| void | setMediator (INDI::BaseMediator *mediator) |
| Set the driver's mediator to receive notification of news devices and updated property values. | |
| INDI::BaseMediator * | getMediator () const |
| void | setDeviceName (const char *dev) |
| Set the device name. | |
| const char * | getDeviceName () const |
| bool | isDeviceNameMatch (const char *otherName) const |
| Check that the device name matches the argument. | |
| bool | isDeviceNameMatch (const std::string &otherName) const |
| Check that the device name matches the argument. | |
| const char * | getDriverName () const |
| const char * | getDriverExec () const |
| const char * | getDriverVersion () const |
| uint16_t | getDriverInterface () const |
| getDriverInterface returns ORed values of DRIVER_INTERFACE. It presents the device classes supported by the driver. | |
| bool | buildSkeleton (const char *filename) |
| Build driver properties from a skeleton file. | |
| int | buildProp (const INDI::LilXmlElement &root, char *errmsg, bool isDynamic=false) |
| Build a property given the supplied XML element (defXXX) | |
| int | setValue (const INDI::LilXmlElement &root, char *errmsg) |
| handle SetXXX commands from client | |
| operator BaseDevice * () | |
| BaseDevice * | operator-> () |
| bool | operator!= (std::nullptr_t) const |
| bool | operator== (std::nullptr_t) const |
| operator bool () const | |
| operator bool () | |
| Public Member Functions inherited from INDI::PACInterface | |
| uint32_t | GetCapability () const |
| void | SetCapability (uint32_t cap) |
| SetCapability sets the PAC device capabilities. Call this in the driver constructor. | |
| bool | HasSpeed () |
| bool | CanReverse () |
| bool | HasPosition () |
| bool | CanHome () |
| bool | HasBacklash () |
| bool | CanSync () |
Protected Member Functions | |
| bool | initProperties () override |
| initProperties | |
| bool | updateProperties () override |
| updateProperties | |
| bool | saveConfigItems (FILE *fp) override |
| saveConfigItems | |
| bool | Handshake () |
| Handshake. | |
| void | TimerHit () override |
| TimerHit. | |
| IPState | MoveAZ (double degrees) override |
| PACInterface – axis movement. | |
| IPState | MoveALT (double degrees) override |
| MoveALT. | |
| IPState | MoveBoth (double azDegrees, double altDegrees) override |
| double | applyCorrectionAZ (double azDegrees) const |
| Scale a requested azimuth step by the configured correction percentage. | |
| double | applyCorrectionALT (double altDegrees) const |
| applyCorrectionALT – correction percentage, or full error + overshoot | |
| bool | AbortMotion () override |
| PACInterface – abort, speed and reverse. | |
| bool | SetPACSpeed (uint16_t speed) override |
| SetPACSpeed (SLvl: 1–5) | |
| bool | ReverseAZ (bool enabled) override |
| ReverseAZ. | |
| bool | ReverseALT (bool enabled) override |
| ReverseALT. | |
| bool | SetHome () override |
| PACInterface – home management. | |
| IPState | GoHome () override |
| GoHome. | |
| bool | ResetHome () override |
| ResetHome. | |
| bool | SyncAZ (double degrees) override |
| PACInterface – sync. | |
| bool | SyncALT (double degrees) override |
| SyncALT – same mechanism as SyncAZ. | |
| bool | SetBacklashEnabled (bool enabled) override |
| PACInterface – backlash. | |
| bool | SetBacklashAZ (int32_t steps) override |
| SetBacklashAZ. | |
| bool | SetBacklashALT (int32_t steps) override |
| SetBacklashALT. | |
| Protected Member Functions inherited from INDI::DefaultDevice | |
| void | setDynamicPropertiesBehavior (bool defineEnabled, bool deleteEnabled) |
| setDynamicPropertiesBehavior controls handling of dynamic properties. Dynamic properties are those generated from an external skeleton XML file. By default all properties, including dynamic properties, are defined to the client in ISGetProperties(). Furthermore, when űdeleteProperty(properyName) is called, the dynamic property is deleted by default, and can only be restored by calling buildSkeleton(filename) again. However, it is sometimes desirable to skip the definition of the dynamic properties on startup and delegate this task to the child class. To control this behavior, set enabled to false. | |
| virtual bool | loadConfig (bool silent=false, const char *property=nullptr) |
| Load the last saved configuration file. | |
| bool | loadConfig (INDI::Property &property) |
| Load property config from the configuration file. If the property configuration is successfully parsed, the corresponding ISNewXXX is called with the values parsed from the config file. | |
| virtual bool | saveConfig (bool silent=false, const char *property=nullptr) |
| Save the current properties in a configuration file. | |
| bool | saveConfig (INDI::Property &property) |
| Save a property in the configuration file. | |
| virtual bool | purgeConfig () |
| purgeConfig Remove config file from disk. | |
| virtual bool | saveAllConfigItems (FILE *fp) |
| saveAllConfigItems Save all the drivers' properties in the configuration file | |
| virtual bool | loadDefaultConfig () |
| Load the default configuration file. | |
| void | setDebug (bool enable) |
| Toggle driver debug status A driver can be more verbose if Debug option is enabled by the client. | |
| void | setSimulation (bool enable) |
| Toggle driver simulation status A driver can run in simulation mode if Simulation option is enabled by the client. | |
| virtual void | debugTriggered (bool enable) |
| Inform driver that the debug option was triggered. This function is called after setDebug is triggered by the client. Reimplement this function if your driver needs to take specific action after debug is enabled/disabled. Otherwise, you can use isDebug() to check if simulation is enabled or disabled. | |
| virtual void | simulationTriggered (bool enable) |
| Inform driver that the simulation option was triggered. This function is called after setSimulation is triggered by the client. Reimplement this function if your driver needs to take specific action after simulation is enabled/disabled. Otherwise, you can use isSimulation() to check if simulation is enabled or disabled. | |
| bool | isDebug () const |
| bool | isSimulation () const |
| virtual bool | Connect () |
| Connect to the device. INDI::DefaultDevice implementation connects to appropriate connection interface (Serial or TCP) governed by connectionMode. If connection is successful, it proceed to call Handshake() function to ensure communication with device is successful. For other communication interface, override the method in the child class implementation. | |
| virtual bool | Disconnect () |
| Disconnect from device. | |
| void | registerConnection (Connection::Interface *newConnection) |
| registerConnection Add new connection plugin to the existing connection pool. The connection type shall be defined to the client in ISGetProperties() | |
| bool | unRegisterConnection (Connection::Interface *existingConnection) |
| unRegisterConnection Remove connection from existing pool | |
| Connection::Interface * | getActiveConnection () |
| void | setActiveConnection (Connection::Interface *existingConnection) |
| setActiveConnection Switch the active connection to the passed connection plugin | |
| void | setDefaultPollingPeriod (uint32_t msec) |
| setDefaultPollingPeriod Change the default polling period to call TimerHit() function in the driver. | |
| void | setPollingPeriodRange (uint32_t minimum, uint32_t maximum) |
| setPollingPeriodRange Set the range permitted by the polling range in milliseconds | |
| uint32_t | getPollingPeriod () const |
| getPollingPeriod Return the polling period. | |
| void | setCurrentPollingPeriod (uint32_t msec) |
| setCurrentPollingPeriod Change the current polling period to call TimerHit() function in the driver. | |
| uint32_t | getCurrentPollingPeriod () const |
| getCurrentPollingPeriod Return the current polling period. | |
| uint32_t & | refCurrentPollingPeriod () __attribute__((deprecated)) |
| uint32_t | refCurrentPollingPeriod () const __attribute__((deprecated)) |
| bool | isConfigLoading () const |
| isConfigLoading Check if driver configuration is currently in the process of getting loaded. | |
| bool | isInitializationComplete () const |
| isInitializationComplete Check if driver initialization is complete. | |
| void | syncDriverInfo () |
| syncDriverInfo sends the current driver information to the client. | |
| void | setDeviceNickname (const char *nick) |
| Set the device nickname. | |
| const char * | getDeviceNickname () |
| const char * | lookupDeviceNicknameFromId (const char *identifier, const char *device=nullptr) |
| Lookup device nickname for an identifier. | |
| bool | setDeviceNicknameFromId (const char *identifier) |
| Set device nickname based on an identifier. | |
| void | saveNicknameId (const char *nickname, const char *identifier) |
| virtual void | nicknameSet (const char *nickname) |
| Inform driver that the nickname has been set. | |
| DefaultDevice (const std::shared_ptr< DefaultDevicePrivate > &dd) | |
| Protected Member Functions inherited from INDI::ParentDevice | |
| ParentDevice (const std::shared_ptr< ParentDevicePrivate > &dd) | |
| Protected Member Functions inherited from INDI::BaseDevice | |
| BaseDevice (BaseDevicePrivate &dd) | |
| BaseDevice (const std::shared_ptr< BaseDevicePrivate > &dd) | |
| Protected Member Functions inherited from INDI::PACInterface | |
| PACInterface (DefaultDevice *device) | |
| virtual | ~PACInterface ()=default |
| void | initProperties (const char *group) |
| initProperties Initialize PAC properties. Call this from your driver's initProperties(). | |
| bool | updateProperties () |
| updateProperties Define or delete properties based on connection state. Call this from your driver's updateProperties(). | |
| bool | processSwitch (const char *dev, const char *name, ISState *states, char *names[], int n) |
| Process PAC switch properties. | |
| bool | processNumber (const char *dev, const char *name, double values[], char *names[], int n) |
| Process PAC number properties. | |
| bool | saveConfigItems (FILE *fp) |
| saveConfigItems Save PAC interface properties to config file. Call this from your driver's saveConfigItems(). | |
Detailed Description
The MLAstroRPA class drives the MLAstro Robotic Polar Alignment controller via its ESP32-based serial protocol.
Protocol summary:
- Handshake: [MLAstroRPA-TC]
→ ok
(older firmware) or ok,firmware X.Y.Z,SN:AA:BB:CC:DD:EE:F0
(newer) - Telemetry: ?
→ <STATUS|Mpos:X.XXXXX,Y.YYYYY|>DATA_SETTING - Relative move (AZ): JoRe:1, ReDe:D,ReAM:M,ReAS:S, MAzL:1 or MAzR:1
- Relative move (ALT): JoRe:1, ReDe:D,ReAM:M,ReAS:S, MAlU:1 or MAlD:1
- Stop: STOP:1
(smooth deceleration) - Speed: SLvl:X
(1–5) - Home: SetH:1
/ RetH:1
/ RstH:1
- Sync: SetH:1
(marks current position as 0,0 reference) - Backlash: Back:X
, AzBl:X
, AlBl:X
- Alt overshoot (2-leg P.A routine): Over:X
, OvUp:X
, OvDn:X
, OvD:X
, OvM:X
, OvS:X
When enabled for a given direction, a downward altitude move overshoots the target and returns upward for the final approach so the platform always comes to rest moving up, which settles more stably than a final downward approach. - Reverse: AzRD:X
, AlRD:X
- Motor config: chained commands + Save&Reboot:1
- Network: STAs:X
, STAp:X
, APss:X
, APpa:X
, APip:X
(set-only; requires Save&Reboot to persist). Password fields are write-only in the driver — never read back, never saved to the local config.
Capabilities: PAC_HAS_SPEED | PAC_CAN_REVERSE | PAC_HAS_POSITION | PAC_CAN_HOME | PAC_HAS_BACKLASH | PAC_CAN_SYNC
Client-side correction shaping (Correction tab), mirroring MLAstro's N.I.N.A. plugin:
- Correction Percentage (default 75%, 1-100%) is applied to Azimuth on every automated correction and to Altitude when the software overshoot is not active for the current correction direction.
- Software Overshoot (ALT): when enabled for the current direction, the Alt axis corrects 100% of the error and then travels the configured overshoot (0-240 arcmin) past the target so the platform always settles from the same direction.
Definition at line 70 of file mlastro_rpa.h.
Constructor & Destructor Documentation
◆ MLAstroRPA()
| MLAstroRPA::MLAstroRPA | ( | ) |
Constructor.
Definition at line 39 of file mlastro_rpa.cpp.
◆ ~MLAstroRPA()
|
overridevirtualdefault |
Member Function Documentation
◆ AbortMotion()
|
overrideprotectedvirtual |
PACInterface – abort, speed and reverse.
AbortMotion.
Reimplemented from INDI::PACInterface.
Definition at line 976 of file mlastro_rpa.cpp.
◆ applyCorrectionALT()
|
protected |
applyCorrectionALT – correction percentage, or full error + overshoot
Scale a requested altitude step by the correction percentage, or apply the full error plus the configured overshoot when the driver-side correction overshoot is active for the move direction.
Definition at line 850 of file mlastro_rpa.cpp.
◆ applyCorrectionAZ()
|
protected |
Scale a requested azimuth step by the configured correction percentage.
applyCorrectionAZ – scale a requested step by the correction percentage
Definition at line 842 of file mlastro_rpa.cpp.
◆ getDefaultName()
|
overridevirtual |
◆ GoHome()
|
overrideprotectedvirtual |
◆ Handshake()
|
protected |
Handshake.
Definition at line 320 of file mlastro_rpa.cpp.
◆ initProperties()
|
overrideprotectedvirtual |
initProperties
Reimplemented from INDI::DefaultDevice.
Definition at line 62 of file mlastro_rpa.cpp.
◆ ISNewNumber()
|
overridevirtual |
ISNewNumber.
Reimplemented from INDI::DefaultDevice.
Definition at line 1226 of file mlastro_rpa.cpp.
◆ ISNewSwitch()
|
overridevirtual |
ISNewSwitch.
Reimplemented from INDI::DefaultDevice.
Definition at line 1379 of file mlastro_rpa.cpp.
◆ ISNewText()
|
overridevirtual |
◆ MoveALT()
|
overrideprotectedvirtual |
◆ MoveAZ()
|
overrideprotectedvirtual |
PACInterface – axis movement.
MoveAZ.
Reimplemented from INDI::PACInterface.
Definition at line 874 of file mlastro_rpa.cpp.
◆ MoveBoth()
|
overrideprotectedvirtual |
MoveBoth Uses the MLAstro alignment chained command to move both axes with a single serial command. The device handles the AZ→ALT sequencing internally and the completion is detected via telemetry (STATUS transitions from ALIGNING to ALIGN_COMPLETED / READY), exactly like single-axis alignment moves.
Reimplemented from INDI::PACInterface.
Definition at line 910 of file mlastro_rpa.cpp.
◆ ResetHome()
|
overrideprotectedvirtual |
◆ ReverseALT()
|
overrideprotectedvirtual |
◆ ReverseAZ()
|
overrideprotectedvirtual |
◆ saveConfigItems()
|
overrideprotectedvirtual |
saveConfigItems
Reimplemented from INDI::DefaultDevice.
Definition at line 294 of file mlastro_rpa.cpp.
◆ SetBacklashALT()
|
overrideprotectedvirtual |
SetBacklashALT.
Reimplemented from INDI::PACInterface.
Definition at line 1205 of file mlastro_rpa.cpp.
◆ SetBacklashAZ()
|
overrideprotectedvirtual |
SetBacklashAZ.
Reimplemented from INDI::PACInterface.
Definition at line 1184 of file mlastro_rpa.cpp.
◆ SetBacklashEnabled()
|
overrideprotectedvirtual |
PACInterface – backlash.
SetBacklashEnabled.
Reimplemented from INDI::PACInterface.
Definition at line 1163 of file mlastro_rpa.cpp.
◆ SetHome()
|
overrideprotectedvirtual |
PACInterface – home management.
SetHome.
Reimplemented from INDI::PACInterface.
Definition at line 1054 of file mlastro_rpa.cpp.
◆ SetPACSpeed()
|
overrideprotectedvirtual |
SetPACSpeed (SLvl: 1–5)
Reimplemented from INDI::PACInterface.
Definition at line 991 of file mlastro_rpa.cpp.
◆ SyncALT()
|
overrideprotectedvirtual |
SyncALT – same mechanism as SyncAZ.
Reimplemented from INDI::PACInterface.
Definition at line 1143 of file mlastro_rpa.cpp.
◆ SyncAZ()
|
overrideprotectedvirtual |
PACInterface – sync.
SyncAZ – marks current position as the AZ reference (zero) The device has no arbitrary-value position sync, so any sync operation calls SetH:1 which zeros both axes simultaneously.
Reimplemented from INDI::PACInterface.
Definition at line 1122 of file mlastro_rpa.cpp.
◆ TimerHit()
|
overrideprotectedvirtual |
◆ updateProperties()
|
overrideprotectedvirtual |
updateProperties
Reimplemented from INDI::DefaultDevice.
Definition at line 234 of file mlastro_rpa.cpp.
The documentation for this class was generated from the following files:
